|
Yinxi Wang | 王印熹 Hi there! I'm a second-year undergraduate student at Peking University, majoring in Artificial Intelligence. Currently, I am a research intern at the HMI Lab at Peking University, advised by Prof. Shanghang Zhang. My research focuses on humanoid loco-manipulation and dexterous manipulation toward generalizable physical intelligence. |

|
News
|
Selected PublicationsI study how robots can coordinate whole-body movement and skillful object interaction, with a focus on humanoid loco-manipulation and dexterous manipulation. Equal contribution Project lead |

|
See What I Need, Dream What I Want: A Navigation Foundation Model on a Self-Constructed Representation Space
Jiawei Chen*, Yinxi Wang, Zihan Yang*, Meijun Gao*, Yaowei Liu*, Shuming Zhang*, Zecheng Li, Xiangju Mi, Yuxuan Liu, Runzhong Huang, Tianlin Li, Xun Zhang, Zhengyang Wang, Xu Miao, Tong Yang arXiv preprint, 2026 Project / Paper RepresentNav learns what to see and predicts the world ahead, enabling goal-directed navigation, instruction following, and visual tracking in cluttered, dynamic environments. |
|
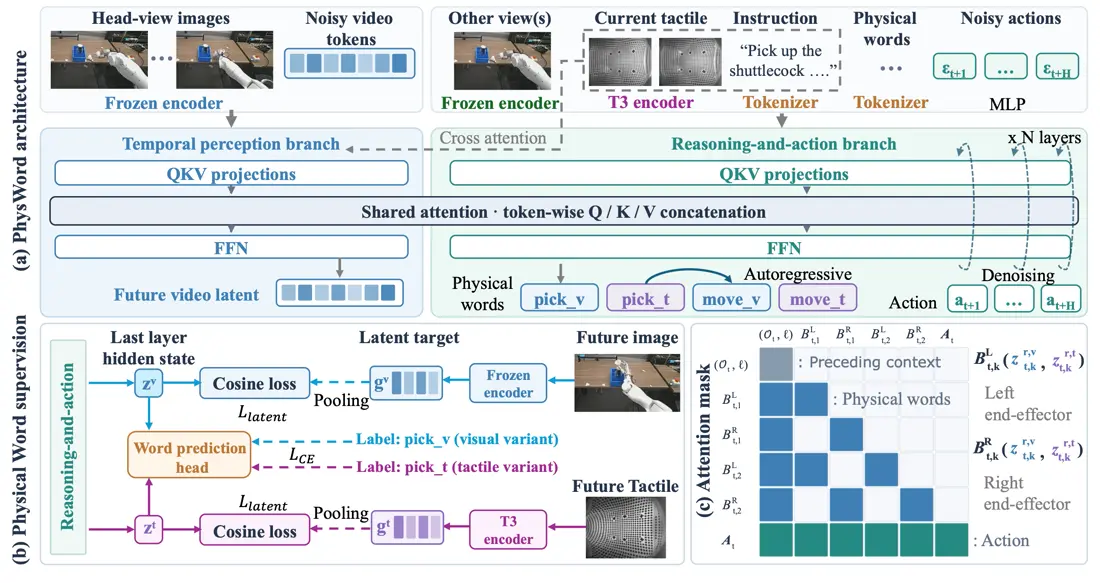
Physical Words: A Vocabulary for Structuring Latent Reasoning in Robot Manipulation
Jiaming Liu*, Xinghao Zhu*, Yiming Zhang*, Shanghang Zhang*, Yinxi Wang, Yichu Yang, Zhuoyang Liu, Dantong Niu, Soha Pouya, Juekun Li, Yan Chang arXiv preprint, 2026 arXiv / Project Connects atomic action words with visual and tactile dynamics to support precise, contact-rich robot manipulation across bimanual and dexterous-hand systems. |
|
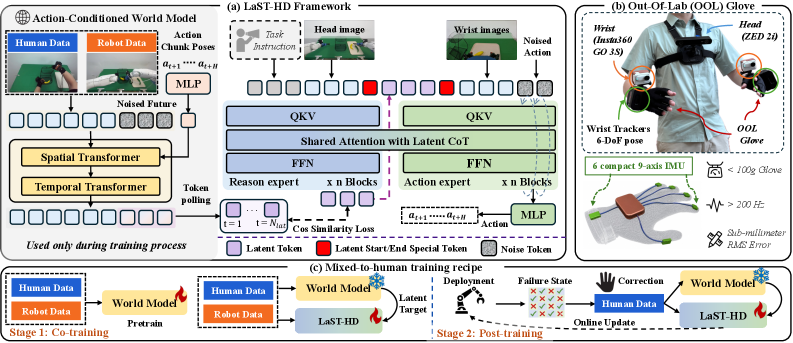
LaST-HD: Learning Latent Physical Reasoning from Scalable Human Data for Robot Manipulation
Jiaming Liu*, Yinxi Wang*, Chenyang Gu*, Siyuan Qian*, Xiangju Mi*, Hao Chen, Jiawei Chen, Qingpo Wuwu, Xiaoqi Li, Nuowei Han, Yiming Zhang, Xuheng Zhang, Yang Yue, Yeqing Yang, Lei Wang, Peng Jia, Hao Tang, Shanghang Zhang arXiv preprint, 2026 arXiv / Project / Code Aligns human-hand and robot demonstrations in a shared latent space through an action-conditioned world model, enabling low-cost, data-efficient transfer of physical reasoning to robot manipulation. |
|
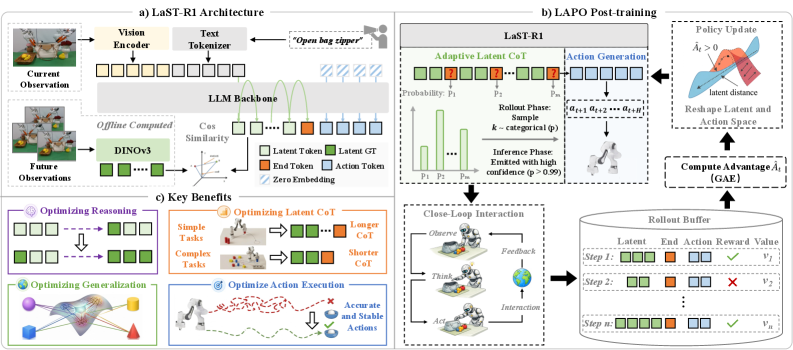
LaST-R1: Reinforcing Robotic Manipulation via Adaptive Physical Latent Reasoning
Hao Chen*, Jiaming Liu*, Zhonghao Yan*, Nuowei Han*, Renrui Zhang, Chenyang Gu, Jialin Gao, Ziyu Guo, Siyuan Qian, Yinxi Wang, Peng Jia, Shanghang Zhang, Pheng-Ann Heng NeurIPS, 2026 arXiv / Project / Code A reinforcement-learning framework that lets a VLA policy perform adaptive latent chain-of-thought reasoning before acting, sharply improving manipulation generalization and execution stability. |
Education |
|
Peking University
B.S. in Artificial Intelligence 2025.09 - Present |
Research Experience |
|
NVIDIA
2026.07 - present Robotics |
|
Simplexity Robotics
2026.01 - 2026.09 Research on Embodied AI and Robot Manipulation |
|
Peking University
HMI (Human Machine Intelligence) Lab 2026.01 - Present
Embodied AI |
|
Design adapted from Jon Barron's template. |